| Product model |
Alternative model |
Product images |
Product description |
View details |
| HM-BLDC1210-C |
Coreless Brushless DC Motor for Dexterous Hands |
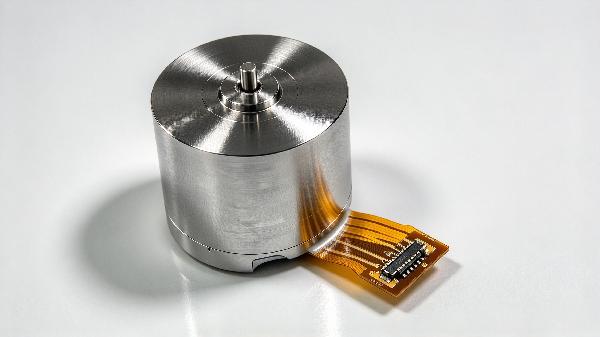 |
10 mm diameter coreless brushless DC servo motor with Hall sensors; customizable encoders available upon request. Application: Primarily used in the palms of high-DOF (Degrees of Freedom) bionic hands to drive finger joints. Benefiting from the low inertia of its coreless rotor, the motor achieves millisecond-level response. |
View details |
| HM-BLDC1010-C |
Coreless Brushless DC Motor for Dexterous Hands |
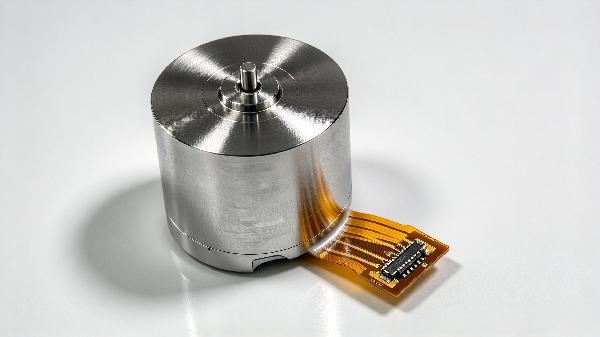 |
10 mm diameter coreless brushless DC servo motor with Hall sensors; customizable encoders available upon request.
Application: Primarily used in the palms of high-DOF (Degrees of Freedom) bionic hands to drive finger joints. Benefiting from the low inertia of its coreless rotor, the motor achieves millisecond-level response. |
View details |
| HM-283835-EC-max-D16mm |
16 mm diameter, 8 W brushless motor with Hall sensors |
|
Suitable for lens focusing in infrared thermal imaging systems, such as autofocus in industrial inspection infrared thermal imagers, spectrometers, and other optical instruments, as well as for robotic vision systems (e.g., humanoid robots). |
View details |
| HM-ECX-TORQUE-D22mm |
22 mm diameter, brushless motor with Hall sensors |
|
Compared to equivalent maxon motors, this motor offers distinct advantages in power and torque output. It is primarily used in professional/competitive-grade RC aircraft (micro UAVs), robot attitude adjustment servos, and gimbal drive applications—such as the gimbal pitch-axis motors for racing drones and high-end aerial photography drones, or the |
View details |
| HM-305015-EC-4pole-D30mm |
30 mm diameter, 200 W brushless motor |
|
Compared to equivalent maxon motors, this motor is nearly identical in speed, current, and torque output. It is primarily used for knee or hip joint actuation in high-performance quadruped robots (robotic dogs), as well as for joint modules in collaborative robots. |
View details |